Urgent.News

What's breaking now, across thousands of outlets.

AI

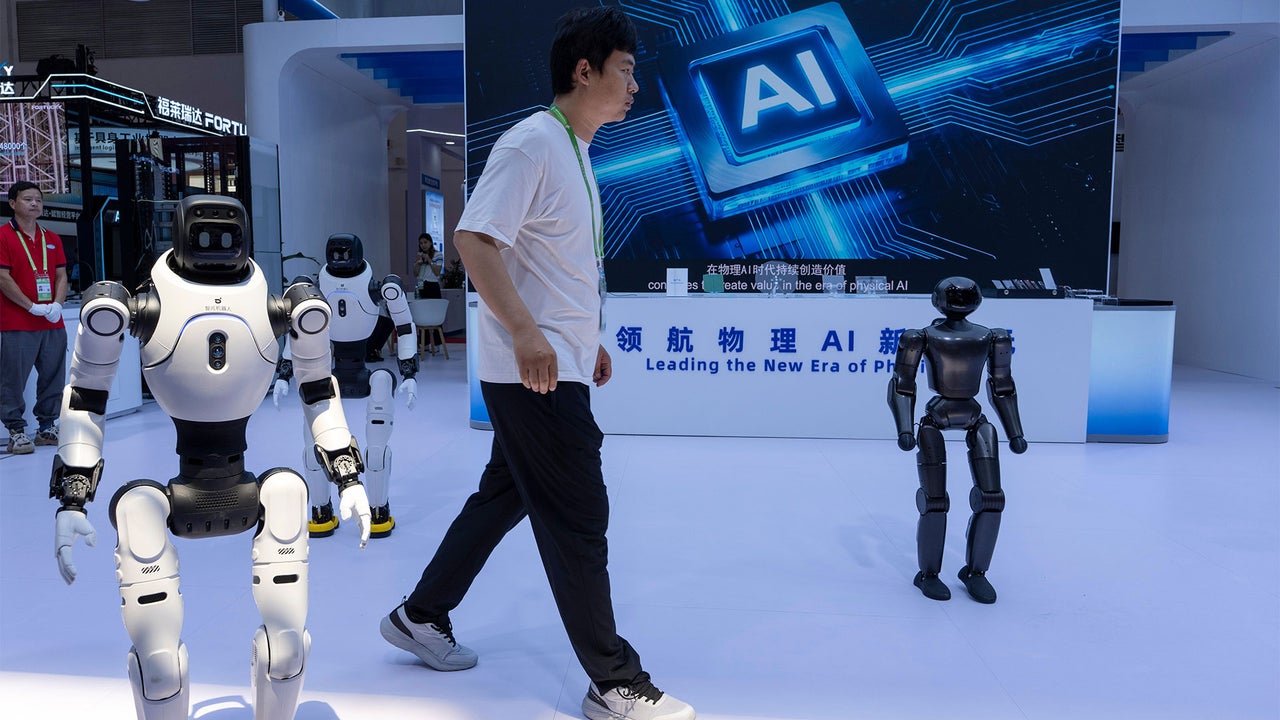
Controlling Collectives of AI Agents in Reasoning Space with Spatial Transformers

Large Language Models (LLMs) introduce an exciting new paradigm for planning and navigation in robotics, but fail on even simple multi-robot tasks as team sizes grow. We propose COMPASS, a scalable, decentralized multi-robot architecture for controlling large collectives of agentic robots with reasoning space feedback control. Feedback is generated locally on each robot by a spatial transformer…

We haven't written up this one. arXiv cs.AI has the full story — the link below goes straight to it.
Read the original at arxiv.org →

More in AI

End-to-End Smart Glasses Jetson ROS 2 Optimization

End-to-End Smart Glasses → Jetson → ROS 2 Optimization Modern Physical AI systems are distributed pipelines. The goal is not simply higher FPS; it is predictable latency, controlled memory use…

  • Establish baseline benchmark for smart glasses system
  • Isolate performance bottlenecks in capture, transfer, decode stages
  • Optimize latency-intensive stage to improve overall performance

Smart Glasses Distributed AI Inference

Smart Glasses Distributed AI Inference Modern Physical AI systems are distributed pipelines. The goal is not simply higher FPS; it is predictable latency, controlled memory use, reasonable power…

More from Wednesday 23 September →